Mechatronics · FH Aachen
Building across mechanics, electronics, and control — robots, rockets, and systems that have to work outside the notebook.
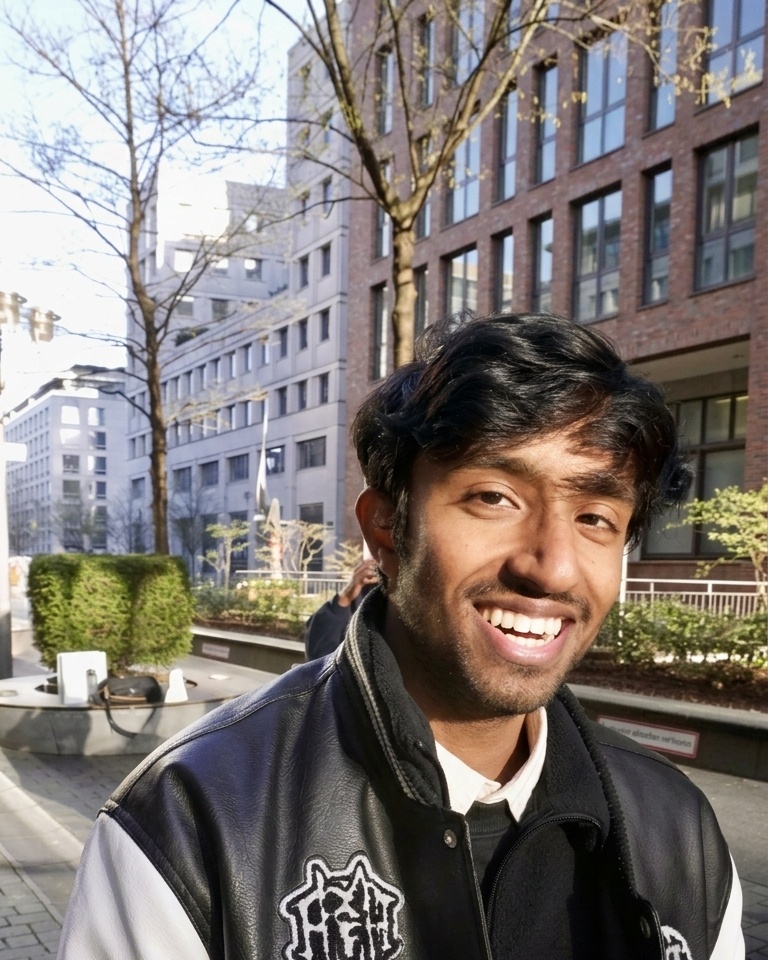
I'm Atharva Edake, a Mechatronics Masters student at FH Aachen, Germany. I'm a hands-on engineer who works across mechanics, electronics, and control logic to build systems that actually work. I follow a structured approach — plan, build, test, debug — and I'm known for moving fast when the first approach doesn't. Outside the lab, I'm either on a long cycling ride or deep into a documentary about science, space, or engineering.
German: B2–C1 · English: C2
Right now In Aachen for the M.Sc. — control, MEMS, and electromechanical systems. Latest build: the ARAMS hospital autonomy stack (ROS 2 + YOLO).
"Curiosity sparks the question. Problems demand the answer. Everything in between — the breaking, the building, the failing, the fixing — that is engineering."
I didn't choose engineering because I knew exactly what I wanted to build. I chose it because I was curious — about how things work, why they fail, and what happens when you take them apart and put them back together differently. That curiosity has never left.
I was never interested in just one subject. Mechatronics gave me the freedom to work across mechanical systems, electronics, and software — all at once. For me it was never about being a specialist. It was about understanding how all three work together in the real world and using that to build things that actually function.
Studying in a different country gives you far more than a degree. Germany opened my perspective — not just to a different style of engineering education, but to a completely different way of thinking, working, and seeing the world. That exposure, outside the classroom as much as inside it, is something you cannot get anywhere else.
Engineering to me is the process of creating something from absolutely nothing. An idea exists. Nothing else does. Then through curiosity, problem solving, failure, iteration, and persistence — something real exists. That cycle — from zero to working product — is what drives me every single day.
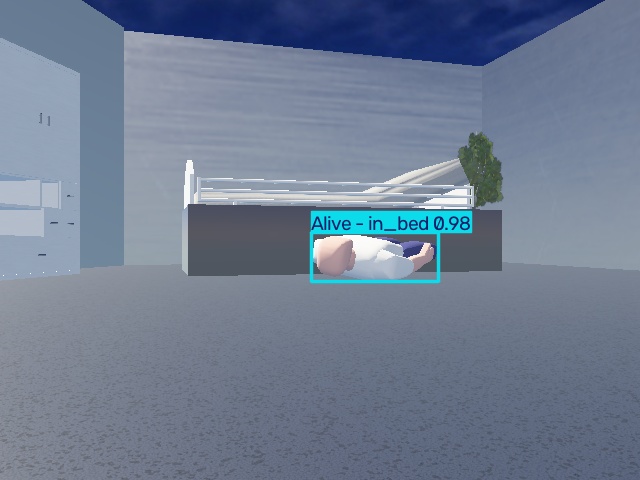
ROS 2 hospital autonomy final project: AMCL localization, AprilTag room selection, Nav2 navigation, door control, and custom YOLOv8 patient-state detection under a Mission Manager.
Bachelor's thesis. Designed a thrust vector control system for finless model rockets using ESP32, MPU6050 IMU, Kalman filter, and PID control tuned via Ziegler-Nichols method.
ESP8266 plant monitor measuring soil moisture and light levels, sending JSON telemetry via HTTPS POST, with Docker-based data capture on the receiver side.
End-to-end integration of an Arduino UNO R3 line-following car with ultrasonic sensing, iterative calibration across runs to reduce path deviation and improve lap time.
Arduino Nano mini-satellite prototype with IMU, temperature sensor, and MQTT telemetry over Wi-Fi. Modes for orientation display, thermal SOS alerts, and motion detection.
Studying analog & digital control, MEMS, advanced engineering mathematics, and electromechanical systems design.
Control Systems · MEMS · Embedded Systems
Graduated with thesis on Design and Implementation of Thrust Vector Control in Rockets. 210 credit points completed.
Robotics · TVC · Embedded Systems
Machined steel and aluminium components on manual and CNC lathes to tolerances down to 0.0127mm. Performed SAW and TIG welding to produce manufacturing-ready assemblies. Migrated legacy technical drawings to Autodesk Fusion 360, aligning them with DIN standards and current manufacturing tolerances.
CNC Machining · TIG Welding · Fusion 360 · DIN Standards
Certifications: Python — Udemy, 2021 · SMSCP Level 1 — Siemens, 2022 · SMSCP Level 2 — Siemens, 2022 · Control System Design — MathWorks, 2026
Collaborations, roles, or a straight question. Email is the reliable path; LinkedIn works too.
Open email